
Overview
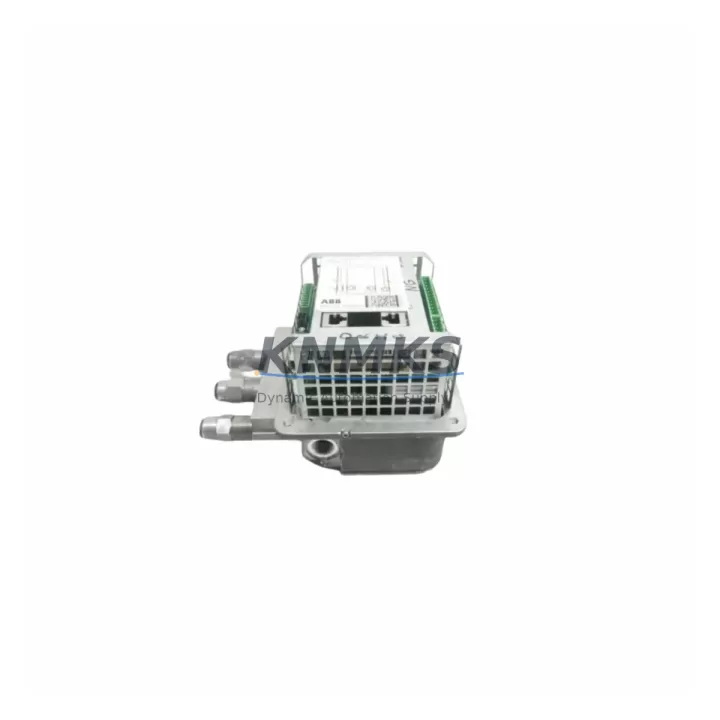
ABB 3HNA024871-001ACU-01B Migration-Ready Axis Gearbox for Legacy Control Systems
The ABB 3HNA024871-001ACU-01B is a precision-engineered axis gearbox designed for ABB IRB series industrial robots. As legacy robot systems approach end-of-life and OEM spare part availability declines, the 3HNA024871-001ACU-01B serves as a critical migration-ready replacement component for maintenance teams managing aging production lines. Whether you are executing a planned overhaul of a multi-axis welding cell or responding to an unplanned gearbox failure on a paint or assembly robot, this unit is pre-tested and ready for drop-in installation into compatible IRB robot arms.
When planning a gearbox replacement on an ABB IRB robot, engineers must confirm several key parameters before committing to installation. Axis assignment is the first checkpoint — the 3HNA024871-001ACU-01B is rated for a specific axis position, and installing it on an incorrect axis will result in torque mismatch, servo tuning errors, and potential mechanical damage. Verify the axis number against the robot’s mechanical unit configuration in RobotStudio or the IRC5 FlexPendant before proceeding. Mounting flange dimensions, bolt pattern, and output shaft interface must be cross-referenced against the original gearbox datasheet to confirm dimensional compatibility, particularly if the robot has undergone any prior non-OEM modification.
Backlash calibration is mandatory after any gearbox replacement. The IRC5 controller — which governs motion control for most IRB 6600, IRB 6640, IRB 7600, and IRB 2600 series robots — requires a full fine calibration sequence using the calibration pendulum or CalibWare software after the new gearbox is seated. Skipping this step will introduce positional drift that accumulates over duty cycles and can compromise weld seam accuracy or pick-and-place repeatability. If the robot is integrated with an ABB DSQC 661 or DSQC 679 axis computer board, confirm that the resolver signal chain is intact and that the SMB (Serial Measurement Board) battery — such as the 3HAC16831-1 — is freshly replaced to avoid loss of revolution counter data during the calibration window.
Lubrication is another field-critical step that is frequently overlooked during emergency replacements. The 3HNA024871-001ACU-01B must be filled with the correct ABB-specified gearbox oil to the prescribed volume before commissioning. Incorrect oil type or insufficient fill level will cause premature bearing wear and void the support terms. Coordinate with your maintenance scheduler to allocate sufficient downtime for oil fill, leak check, and a slow-speed run-in cycle before returning the robot to full production speed.
Migration Compatibility Table
| Parameter | Details |
|---|---|
| SKU | 3HNA024871-001ACU-01B |
| Brand | ABB |
| Compatible Robot Series | ABB IRB Series (IRB 6600, IRB 6640, IRB 7600, IRB 2600 — verify axis assignment) |
| Component Type | Axis Gearbox / Reduction Unit |
| Controller Compatibility | IRC5 Single / IRC5 Panel Mounted / IRC5 Compact |
| Mounting Interface | Flange-mount; confirm bolt pattern and output shaft spec against original unit |
| Calibration Required | Yes — full fine calibration via CalibWare or FlexPendant after installation |
| Lubrication | ABB-specified gearbox oil; fill to prescribed volume before commissioning |
| Replacement Scope | Direct replacement for worn, seized, or discontinued OEM gearbox units |
| Origin | Sweden (SE) |
| Pre-Shipment Testing | Yes — dimensional and functional verification before dispatch |
| Support terms | support terms confirmed by quotation from date of shipment |
| Availability | availability confirmed by RFQ — global shipping supported |
Retrofit Planning for Existing Automation Systems
A successful gearbox retrofit on an ABB IRB robot requires a coordinated approach across mechanical, electrical, and software domains. Before the 3HNA024871-001ACU-01B is installed, the maintenance team should audit the full axis drive chain. This includes inspecting the ABB DSQC 668 drive unit or equivalent axis drive module for any fault history related to overcurrent or overtemperature — conditions that may have contributed to the original gearbox failure. If the drive module shows degraded performance, replacing it concurrently with the gearbox avoids a second unplanned shutdown within the same maintenance cycle.
The IRC5 controller cabinet should also be inspected during the retrofit window. Check the DSQC 661 computer unit for firmware currency and verify that the system software version is compatible with the robot’s current mechanical configuration. If the installation involves an IRB robot that was previously running on an S4C+ controller and has since been migrated to IRC5, confirm that all axis parameters have been correctly imported and that no legacy motion configuration files are conflicting with the new hardware profile.
For robots operating in multi-robot cells coordinated via DeviceNet or PROFIBUS, verify that the axis gearbox replacement does not affect the robot’s position within the coordinated motion group. Any change in fine calibration offsets must be propagated to the MultiMove configuration in RobotStudio and validated against the master program before resuming synchronized operation. The ABB FlexPendant (TP) should be used to jog each axis through its full range of motion at reduced speed before enabling automatic mode.
If the robot is equipped with an external axis positioner or track motion unit, the gearbox replacement on the primary arm must be followed by a full TCP (Tool Center Point) verification using a calibration tool or laser tracker. This is especially important in arc welding applications where TCP accuracy directly affects weld quality and seam tracking performance. Coordinate with the welding process engineer to schedule a short weld qualification run before releasing the cell to production.
Downtime Control During System Migration
Minimizing downtime during a gearbox replacement on a production robot requires pre-staging all replacement components and tools before the robot is taken offline. For the 3HNA024871-001ACU-01B, this means having the correct torque wrenches, oil fill equipment, calibration pendulum, and a laptop with RobotStudio and CalibWare installed and licensed — all ready at the work cell before the shift begins. A pre-planned replacement procedure, reviewed and signed off by the robot programmer and maintenance supervisor, reduces the risk of procedural errors that extend downtime.
Back up the robot’s current system parameters, RAPID programs, and calibration data to a USB drive or network share before any mechanical work begins. This backup protects against data loss if the SMB battery is inadvertently disconnected during the gearbox swap. If the revolution counters are lost, the fine calibration process will take additional time, so preserving this data is a direct downtime reduction measure.
Where production scheduling allows, plan the gearbox replacement during a planned maintenance window rather than as an emergency repair. This allows the oil fill and run-in cycle to be completed without production pressure, and gives the team time to perform a full I/O check and safety function verification — including the robot’s SafeMove configuration if applicable — before returning the robot to automatic operation. A structured commissioning checklist, signed off by the responsible engineer, provides a clear record of the retrofit and supports the support terms confirmed by quotation claim process.
Retrofit Support FAQ
Q: Is the 3HNA024871-001ACU-01B a direct replacement for the original ABB gearbox on my IRB robot?
A: The 3HNA024871-001ACU-01B is designed as a compatible replacement for the corresponding axis gearbox position on ABB IRB series robots. Always verify the axis number, mounting flange dimensions, and output shaft interface against your robot’s mechanical documentation before installation to confirm fitment.
Q: Does the gearbox require calibration after installation?
A: Yes. A full fine calibration sequence is mandatory after any gearbox replacement on an ABB IRB robot. Use CalibWare software or the IRC5 FlexPendant calibration routine. Ensure the SMB battery is functional before starting calibration to avoid revolution counter loss.
Q: What lubrication is required, and is it included with the unit?
A: The gearbox must be filled with ABB-specified gearbox oil to the correct volume before commissioning. Lubrication is not pre-filled in the replacement unit. Refer to the ABB product manual for the correct oil specification and fill volume for your robot model and axis position.
Q: What support terms and testing does KNMKS provide with this unit?
A: Every 3HNA024871-001ACU-01B shipped by KNMKS undergoes pre-shipment dimensional and functional verification. The unit is covered by a support terms confirmed by quotation from the date of shipment. In-stock units are available for immediate dispatch with global shipping support. Contact admin@knmks.com or +86 18359268345 for availability and lead time confirmation.
© 2026 KNMKS. All rights reserved.
Original Source: https://knmks.com
Contact: admin@knmks.com | +86 18359268345
Product Identification
- Brand / Ecosystem
-
ABB
ABB - Model / Series
- 3HNA024871-001ACU-01B
- Product Family
- Other Components
- Availability Status
- Available on request after model and quantity confirmation
- Inquiry Type
- B2B RFQ, replacement inquiry and project spare-part request
- Pre-Quote Check
- Exact SKU, brand, series, quantity, nameplate photos and destination country are checked before quotation
System Path
Where this product fits in the KNMKS automation structure.
Specification & Inquiry Focus
- Component range
- Breakers, terminals and cabinet accessories
- Common needs
- Model, photo and installation requirement
- Project support
- Maintenance and mixed spare-part inquiry
Buyer Confirmation
Information KNMKS checks before replying.
- Exact model
- 3HNA024871-001ACU-01B
- Brand / ecosystem
- ABB
- Product family
- Other Components
- Application note
- Replacement, maintenance, project build or spare-part list
- Useful photos
- Nameplate, installed unit, cabinet layout or connector side
- Delivery details
- Quantity, destination country and target schedule
Document Support
Files and notes can be confirmed during quotation.
- Product photos or nameplate confirmation when available
- Packing and delivery notes before quotation confirmation
- Support scope and delivery terms confirmed per inquiry
- Export document coordination for qualified B2B requests
Inquiry Support
- Mixed automation spare parts inquiry
- Cabinet component and accessory support
- Model identification from photos or labels
What to Send Us
- Brand and exact model number: ABB 3HNA024871-001ACU-01B
- Quantity and required delivery time
- Application, replacement requirement or nameplate photo
- Destination country and shipping preference
RFQ Preparation
This is a product inquiry page built for RFQ communication.
Fast Model Check
Send this model to KNMKS for confirmation.
Include quantity, destination country and photos if this is a maintenance replacement. The inquiry will be saved with a reference number after submission.
Brand & Compatibility Note
KNMKS displays automation product information for well-known industrial brand ecosystems and compatible replacement references. Brand names are used for product identification and compatibility reference only; final availability and commercial terms are confirmed per quotation.
 Manufacturing
 Machine Tools
 Packaging
 Energy & Power
 PLCs & Controllers
 HMI & Displays
 Servo Systems
 Variable Frequency Drives