
Overview
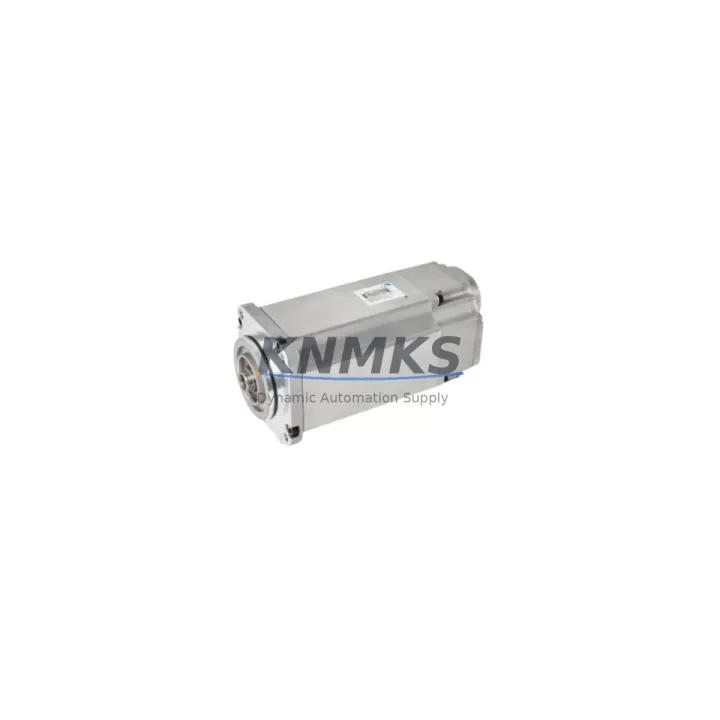
ABB 53HAC10603-1 Migration-Ready AC Servo Motor: Legacy System Retrofit & Upgrade
The ABB 53HAC10603-1 is a migration-ready AC servo motor engineered as a direct replacement for end-of-life and discontinued drive components in the ABB IRB 4400 and IRB 6620 robot platforms. As OEM production of legacy servo assemblies winds down, maintenance engineers and system integrators face increasing pressure to source verified drop-in replacements that preserve existing wiring harnesses, backplane interfaces, and motion control logic without triggering a full system overhaul. The 53HAC10603-1 addresses this challenge by maintaining full mechanical and electrical compatibility with the original installation envelope, enabling controlled, low-risk retrofits across a wide range of industrial automation environments including automotive body-in-white lines, foundry handling cells, and palletizing stations.
Before committing to a replacement, engineers must verify several critical parameters: power supply capacity at the drive cabinet (typically 400–480 V AC, 3-phase), terminal wiring assignments on the motor feedback connector (resolver or EnDat encoder pinout), backplane slot compatibility within the IRC5 or S4C+ controller rack, axis module address configuration in the robot parameter file, and firmware version alignment between the drive unit and the RobotWare release installed on the controller. Mismatches in any of these areas can prevent the robot from completing its mastering sequence or cause axis calibration faults during commissioning.
Migration Compatibility Table
| Parameter | Legacy Reference | 53HAC10603-1 Specification | Retrofit Note |
|---|---|---|---|
| Compatible Platforms | IRB 4400 / IRB 6620 | IRB 4400, IRB 6620, IRB 6640 (axis 1–3) | Confirm robot variant and axis assignment before ordering |
| Alternate SKUs | 63HAC070402-001 / 63HAC066543-001 | 53HAC10603-1 (primary) | Cross-reference OEM part number in robot BOM |
| Feedback Interface | Resolver / EnDat 2.1 | Resolver (standard); EnDat on request | Verify SMB (Serial Measurement Board) firmware compatibility |
| Power Supply | 400–480 V AC, 3-phase | 400–480 V AC, 3-phase | Check drive unit DSQC 661 / DSQC 663 capacity |
| Mounting Interface | Flange-mount, OEM bracket | Identical flange pattern | No bracket modification required |
| Communication Protocol | DeviceNet / PROFIBUS (IRC5) | Compatible via existing axis computer | No fieldbus reconfiguration needed |
| Installation Space | Standard IRB 4400 upper arm | Identical envelope | No mechanical rework required |
| Commissioning | Fine calibration + mastering | Fine calibration required post-swap | Use calibration pendulum or FlexPendant routine |
| Firmware Compatibility | RobotWare 5.x / 6.x | RobotWare 5.13+ / 6.x | Confirm RW version before installation |
| Support terms | — | 12 Months | Covers manufacturing defects; includes pre-shipment functional test |
Retrofit Planning for Existing Automation Systems
A successful servo motor retrofit on an IRB 4400 or IRB 6620 cell requires more than a mechanical swap. The replacement workflow typically begins with a full audit of the IRC5 controller cabinet, including inspection of the DSQC 661 drive unit or DSQC 663 drive module for thermal damage, capacitor aging, and firmware currency. If the drive unit is also approaching end-of-life, it is advisable to replace it concurrently to avoid a second unplanned shutdown within the same maintenance window.
The SMB (Serial Measurement Board) — responsible for reading encoder or resolver signals from all axes — must be checked for firmware compatibility with the replacement motor’s feedback interface. In installations where the SMB firmware predates RobotWare 5.13, an update is mandatory before the new motor will be recognized correctly. Similarly, the axis computer (DSQC 668) should be verified against the current RobotWare release to ensure the axis parameter file can be loaded without conflict.
For cells running DeviceNet or PROFIBUS-DP fieldbus topologies, the motor swap itself does not require any fieldbus reconfiguration — the servo axis communicates through the drive unit, not directly on the fieldbus. However, if the retrofit is part of a broader migration from an S4C+ controller to an IRC5 platform, the fieldbus master configuration, I/O mapping, and DSQC 652 digital I/O module assignments will all need to be re-validated against the updated system architecture.
HMI screens connected via FlexPendant or a third-party SCADA panel should be reviewed for any axis-specific status displays or alarm text that references the original motor serial number or calibration offset. After the motor swap and fine calibration, the mastering offset values stored in the robot parameter file will change, and any HMI trend displays logging torque or position data should be reset to avoid false baseline comparisons. If the cell uses a DSQC 1000 safety controller or external safety PLC for speed monitoring and zone supervision, the safety configuration should be re-validated and a functional safety test performed before returning the cell to production.
Where the retrofit involves multiple robots in a coordinated line — for example, a spot-welding transfer line using IRB 6620 units alongside IRB 4400 material handling robots — it is recommended to stage the replacements across planned maintenance shifts rather than attempting simultaneous swaps. This approach preserves partial line throughput and allows each robot to be individually mastered, tested, and signed off before the next unit is taken offline.
Downtime Control During System Migration
Minimizing unplanned downtime during a servo motor replacement requires a structured pre-outage preparation protocol. Before the maintenance window opens, the replacement ABB 53HAC10603-1 should be bench-tested for free rotation, encoder signal integrity (using a drive tester or oscilloscope on the resolver output), and correct connector pinout against the robot’s wiring diagram. All calibration tools — including the calibration pendulum, FlexPendant with the correct RobotWare version, and a copy of the robot’s current parameter backup — should be staged at the cell before the robot is powered down.
The existing robot program and system parameters should be backed up to a USB drive or network share immediately before the shutdown. This backup preserves the current mastering offsets, I/O configuration, safety zone definitions, and motion program logic, providing a recovery baseline if the commissioning process encounters unexpected faults. The backup also serves as the reference for verifying that the post-swap fine calibration has restored the robot to its original TCP (Tool Center Point) accuracy.
During the physical swap, the motor connector should be labeled and photographed before disconnection to prevent wiring errors on reassembly. The brake release procedure must be followed to avoid dropping the robot arm under gravity during the motor removal phase. After mechanical installation, the drive unit should be powered up in a controlled sequence — first enabling the drive without releasing the brake, confirming that the encoder signal is recognized and the axis fault clears, before proceeding to brake release and motion testing at reduced speed.
Post-installation, fine calibration using the calibration pendulum restores the mastering reference for the affected axis. A slow-speed cycle test through the full working envelope, followed by a production-speed dry run without the end effector, confirms that path accuracy and repeatability are within specification before the robot is returned to the line. Total planned downtime for a single-axis servo swap on an IRB 4400, including preparation, swap, calibration, and sign-off, typically ranges from 4 to 8 hours depending on access conditions and team experience.
Retrofit Support FAQ
Q1: Is the ABB 53HAC10603-1 a direct drop-in replacement for 63HAC070402-001 and 63HAC066543-001?
Yes. The 53HAC10603-1 is cross-referenced as a migration-ready replacement for both 63HAC070402-001 and 63HAC066543-001 in IRB 4400 and IRB 6620 applications. Mechanical mounting, connector pinout, and feedback interface are compatible. Fine calibration is required after installation to restore mastering accuracy.
Q2: What pre-shipment testing is performed on each unit?
Each 53HAC10603-1 undergoes a functional test covering free-rotation check, winding resistance measurement, insulation resistance verification, and encoder/resolver signal output confirmation before dispatch. A test report is available on request. All units are shipped with a support terms confirmed by quotation covering manufacturing defects from the date of delivery.
Q3: Do I need to update the IRC5 firmware before installing this motor?
If the IRC5 controller is running RobotWare 5.13 or later, no firmware update is required for the motor swap itself. For controllers running earlier RobotWare versions, an SMB firmware update is recommended to ensure correct resolver signal interpretation. Contact our technical team with your controller serial number and current RobotWare version for a compatibility confirmation before ordering.
Q4: What is the typical lead time and stock availability?
The ABB 53HAC10603-1 is held availability confirmed by RFQ for immediate dispatch. Standard lead time for in-stock units is 3–7 business days to most destinations. For urgent requirements, expedited shipping options are available. Contact us to confirm current stock levels and delivery timelines for your region.
© 2026 KNMKS. All rights reserved.
Original Source: https://knmks.com
Contact: admin@knmks.com | +86 18359268345
Product Identification
- Brand / Ecosystem
-
ABB
ABB - Model / Series
- IRB44004-53HAC10603-1 IRB66201-63HAC070402-001 IRB66201-63HAC066543-001
- Product Family
- Servo Systems
- Availability Status
- Available on request after model and quantity confirmation
- Inquiry Type
- B2B RFQ, replacement inquiry and project spare-part request
- Pre-Quote Check
- Exact SKU, brand, series, quantity, nameplate photos and destination country are checked before quotation
System Path
Where this product fits in the KNMKS automation structure.
Specification & Inquiry Focus
- Motion range
- Servo drives, motors and cable sets
- Common needs
- Power, encoder and brake confirmation
- Project support
- Motion upgrade and spare-part supply
Buyer Confirmation
Information KNMKS checks before replying.
- Exact model
- IRB44004-53HAC10603-1 IRB66201-63HAC070402-001 IRB66201-63HAC066543-001
- Brand / ecosystem
- ABB
- Product family
- Servo Systems
- Application note
- Replacement, maintenance, project build or spare-part list
- Useful photos
- Nameplate, installed unit, cabinet layout or connector side
- Delivery details
- Quantity, destination country and target schedule
Document Support
Files and notes can be confirmed during quotation.
- Product photos or nameplate confirmation when available
- Packing and delivery notes before quotation confirmation
- Support scope and delivery terms confirmed per inquiry
- Export document coordination for qualified B2B requests
Inquiry Support
- Motor, drive and cable set coordination
- Power rating and encoder type checking
- Motion control replacement support
What to Send Us
- Brand and exact model number: ABB IRB44004-53HAC10603-1 IRB66201-63HAC070402-001 IRB66201-63HAC066543-001
- Quantity and required delivery time
- Application, replacement requirement or nameplate photo
- Destination country and shipping preference
RFQ Preparation
This is a product inquiry page built for RFQ communication.
Fast Model Check
Send this model to KNMKS for confirmation.
Include quantity, destination country and photos if this is a maintenance replacement. The inquiry will be saved with a reference number after submission.
Brand & Compatibility Note
KNMKS displays automation product information for well-known industrial brand ecosystems and compatible replacement references. Brand names are used for product identification and compatibility reference only; final availability and commercial terms are confirmed per quotation.
 Manufacturing
 Machine Tools
 Packaging
 Energy & Power
 PLCs & Controllers
 HMI & Displays
 Variable Frequency Drives
 Sensors