
Overview
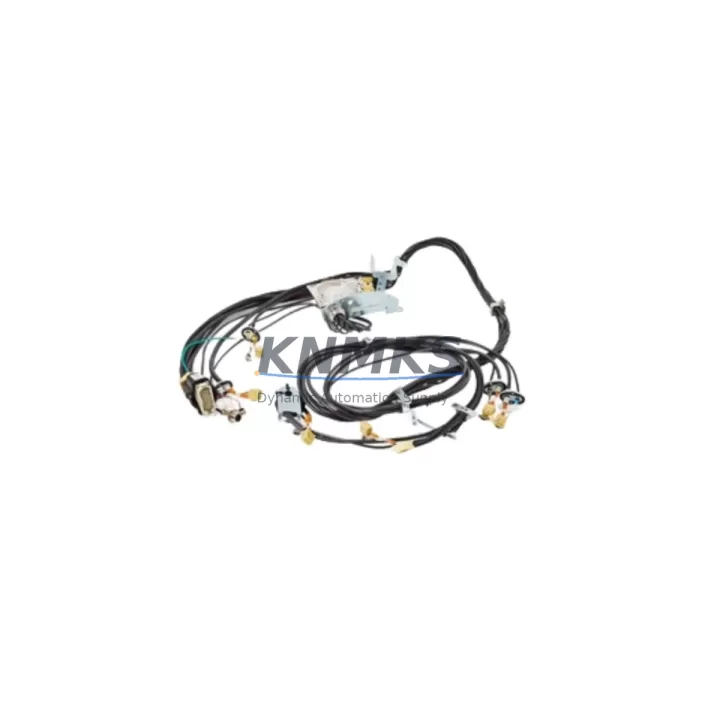
ABB 3HAC034863-005 Migration-Ready Wrist Harness for IRB6640: Legacy System Retrofit & Compatibility Upgrade
The ABB 3HAC034863-005 is the OEM-specification Axis 5/6 wrist harness designed for the IRB6640 and IRB6650S industrial robot platforms. As ABB progressively phases out legacy robot controller generations, maintenance engineers and system integrators managing aging production lines face increasing pressure to source verified replacement cable assemblies that maintain full mechanical and electrical compatibility with existing wrist units, dress packs, and controller I/O mapping. The 3HAC034863-005 addresses this challenge directly: it is a drop-in retrofit harness that preserves original connector pinouts, routing geometry, and signal integrity without requiring modifications to the robot program, teach pendant configuration, or IRC5 controller wiring.
For facilities operating IRB6640-185/2.8, IRB6640-130/3.2, or IRB6650S variants, the wrist harness is a life-cycle-critical spare. Harness degradation — typically presenting as intermittent Axis 5 or Axis 6 resolver faults, SMB (Serial Measurement Board) communication errors, or physical cable abrasion at the wrist housing — is one of the most common causes of unplanned downtime on high-cycle welding, material handling, and press-tending lines. Stocking a verified 3HAC034863-005 unit eliminates the lead-time risk associated with OEM back-order situations and supports a controlled, low-risk swap procedure during planned maintenance windows.
Migration Compatibility Table
| Parameter | Details |
|---|---|
| Compatible Robot Models | IRB6640 (all payload variants), IRB6650S |
| Axis Coverage | Axis 5 & Axis 6 (wrist harness) |
| Connector Interface | OEM-matched; no adapter required for direct replacement |
| Controller Compatibility | IRC5 Single Cabinet, IRC5 Compact, IRC5 Panel Mounted |
| SMB Communication | Compatible with ABB Serial Measurement Board (3HAC14140-1 circuit) |
| Installation Space | Identical routing path to OEM harness; no mechanical modification required |
| Firmware Dependency | No firmware update required; compatible with RobotWare 5.x and 6.x |
| Replacement Recommendation | Direct drop-in; verify resolver calibration (fine calibration) post-installation |
| Commissioning Focus | SMB signal check, resolver offset verification, axis load test at reduced speed |
| Pre-Shipment Testing | Continuity, insulation resistance, and connector seating verified before dispatch |
| Support terms | support terms confirmed by quotation from date of shipment |
| Origin | Germany (DE) |
Retrofit Planning for Existing Automation Systems
A successful wrist harness retrofit on an IRB6640 line requires more than a cable swap. Engineers should approach the replacement as part of a broader mechanical and electrical audit of the robot’s wrist assembly and upper arm dress pack. Before removing the 3HAC034863-005 harness, document the existing cable routing, tie-wrap positions, and any custom strain relief brackets installed during the original system commissioning. This documentation prevents routing errors that can cause premature wear on the new harness.
On the controller side, verify that the IRC5 cabinet’s axis computer — typically the DSQC668 or DSQC679 drive module — is logging clean resolver feedback on Axes 5 and 6 prior to shutdown. If resolver faults are already present, the SMB board (Serial Measurement Board) should be inspected alongside the harness replacement, as SMB degradation and harness failure often occur concurrently on high-cycle installations. The SMB connects directly to the wrist harness signal conductors, and a compromised board will generate false faults even after a new 3HAC034863-005 is installed.
For lines where the IRB6640 operates in tandem with external I/O modules — such as ABB DSQC652 digital I/O units or DSQC643 analog I/O boards mounted in the IRC5 cabinet — confirm that the I/O mapping in the robot program remains unaffected by the harness swap. The 3HAC034863-005 carries only resolver and motor power signals for Axes 5 and 6; it does not route tool I/O or fieldbus signals, so PLC-side DeviceNet or PROFIBUS configurations do not require reconfiguration. However, if the robot is equipped with an integrated wrist-mounted tool changer or servo gripper, verify that the tool cable assembly — a separate harness routed alongside the 3HAC034863-005 — is also in serviceable condition before returning the cell to production.
Facilities upgrading from older IRB6600 platforms to IRB6640 as part of a broader line modernization should note that the wrist harness geometry and connector specification differ between generations. The 3HAC034863-005 is specific to the IRB6640/IRB6650S mechanical platform and is not interchangeable with IRB6600-series harnesses. If the modernization also involves migrating from an S4C+ controller to IRC5, the full axis computer, drive module, and SMB stack must be updated in parallel — the harness alone does not bridge the controller generation gap.
Where the retrofit is part of a control cabinet upgrade — for example, integrating a new Siemens S7-1500 safety PLC or a Rockwell ControlLogix system as the line master controller — the IRC5’s PROFINET or EtherNet/IP adapter configuration should be validated against the new PLC’s I/O table before the robot is returned to automatic mode. The wrist harness replacement itself is mechanically independent of this integration work, but scheduling both tasks within the same maintenance window minimizes total downtime exposure.
Downtime Control During System Migration
Unplanned harness failure on a high-utilization IRB6640 cell can result in 4–12 hours of unplanned downtime when spare parts are not pre-positioned. The most effective downtime control strategy is to maintain at least one verified 3HAC034863-005 unit in the local spare parts cabinet, particularly for lines running two or three shifts with limited maintenance access windows.
When a planned replacement is scheduled, the swap procedure should be executed during a production changeover or scheduled preventive maintenance stop. The robot program does not require modification — the 3HAC034863-005 is a direct electrical and mechanical replacement, and the IRC5 controller retains all axis parameters, tool data, and work object definitions in non-volatile memory. After harness installation, the only mandatory commissioning step is a fine calibration check on Axes 5 and 6 using the FlexPendant calibration routine, followed by a low-speed test cycle to confirm resolver feedback stability before returning to full production speed.
For multi-robot cells where several IRB6640 units share a common IRC5 MultiMove controller, the harness replacement on one robot does not affect the program execution of the remaining robots in the cell. The MultiMove task structure isolates axis feedback per robot, so the maintenance team can perform the swap on one unit while the remaining robots continue operating in a reduced-capacity mode — provided the cell safety logic and area guarding permit single-robot isolation without a full cell stop.
All units are pre-shipment tested for continuity, insulation resistance, and connector seating integrity before dispatch. This eliminates the risk of receiving a defective harness and discovering the fault only after the robot has been taken offline — a scenario that compounds downtime and complicates root-cause analysis. Combined with the support terms confirmed by quotation from date of shipment, the 3HAC034863-005 supplied through this listing provides a verified, low-risk replacement path for maintenance teams operating under tight production schedules.
Retrofit Support FAQ
Q1: Is the 3HAC034863-005 a direct replacement for the original ABB wrist harness on the IRB6640?
Yes. The 3HAC034863-005 is the OEM part number for the Axis 5/6 wrist harness on the IRB6640 and IRB6650S. It is a direct drop-in replacement with identical connector pinouts, cable routing geometry, and signal specifications. No adapter, re-pinning, or mechanical modification is required.
Q2: Does the harness replacement require a robot program update or controller reconfiguration?
No program modification is required. The IRC5 controller retains all axis parameters in non-volatile memory. After installation, perform a fine calibration check on Axes 5 and 6 via the FlexPendant and run a low-speed test cycle to verify resolver feedback before resuming production. No changes to I/O mapping, tool data, or work object definitions are needed.
Q3: What pre-shipment testing is performed, and what support terms is provided?
Each 3HAC034863-005 unit undergoes continuity testing, insulation resistance verification, and connector seating inspection before dispatch. A support terms confirmed by quotation is provided from the date of shipment, covering manufacturing defects and connector integrity.
Q4: Is in-stock inventory available for immediate shipment?
Yes. This listing reflects current in-stock inventory. Orders are processed and dispatched promptly. For urgent requirements or multi-unit orders, contact admin@knmks.com or call +86 18359268345 to confirm availability and lead time before placing your order.
© 2026 KNMKS. All rights reserved.
Original Source: https://knmks.com
Contact: admin@knmks.com | +86 18359268345
Product Identification
- Brand / Ecosystem
-
ABB
ABB - Model / Series
-
IRB6640 3HAC034863-005 3HAC034863-005 IRB6650S 3HAC14140-1
IRC5 Series - Product Family
- Cables & Connectors
- Availability Status
- Available on request after model and quantity confirmation
- Inquiry Type
- B2B RFQ, replacement inquiry and project spare-part request
- Pre-Quote Check
- Exact SKU, brand, series, quantity, nameplate photos and destination country are checked before quotation
System Path
Where this product fits in the KNMKS automation structure.
Specification & Inquiry Focus
- Cable range
- Sensor, servo, network and circular connectors
- Common needs
- Length, pin count, shielding and plug type
- Project support
- Machine wiring and installation kits
Buyer Confirmation
Information KNMKS checks before replying.
- Exact model
- IRB6640 3HAC034863-005 3HAC034863-005 IRB6650S 3HAC14140-1
- Brand / ecosystem
- ABB
- Product family
- Cables & Connectors
- Application note
- Replacement, maintenance, project build or spare-part list
- Useful photos
- Nameplate, installed unit, cabinet layout or connector side
- Delivery details
- Quantity, destination country and target schedule
Document Support
Files and notes can be confirmed during quotation.
- Product photos or nameplate confirmation when available
- Packing and delivery notes before quotation confirmation
- Support scope and delivery terms confirmed per inquiry
- Export document coordination for qualified B2B requests
Inquiry Support
- Cable length and connector type confirmation
- Servo, sensor and network cable inquiry
- Accessory kits for installation teams
What to Send Us
- Brand and exact model number: ABB IRB6640 3HAC034863-005 3HAC034863-005 IRB6650S 3HAC14140-1
- Quantity and required delivery time
- Application, replacement requirement or nameplate photo
- Destination country and shipping preference
RFQ Preparation
This is a product inquiry page built for RFQ communication.
Fast Model Check
Send this model to KNMKS for confirmation.
Include quantity, destination country and photos if this is a maintenance replacement. The inquiry will be saved with a reference number after submission.
Brand & Compatibility Note
KNMKS displays automation product information for well-known industrial brand ecosystems and compatible replacement references. Brand names are used for product identification and compatibility reference only; final availability and commercial terms are confirmed per quotation.
 Manufacturing
 Machine Tools
 Packaging
 Energy & Power


 PLCs & Controllers
 HMI & Displays
 Servo Systems
 Variable Frequency Drives